#include <abstractrobot.h>
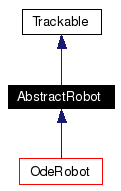
Inheritance diagram for AbstractRobot:
Definition at line 78 of file abstractrobot.h.
Public Member Functions | |
| AbstractRobot (const char *name="abstractRobot") | |
| Constructor. | |
| virtual | ~AbstractRobot () |
| string | getName () const |
| returns the name of the robot | |
| virtual int | getSensors (sensor *sensors, int sensornumber)=0 |
| returns actual sensorvalues | |
| virtual void | setMotors (const motor *motors, int motornumber)=0 |
| sets actual motorcommands | |
| virtual int | getSensorNumber ()=0 |
| returns number of sensors | |
| virtual int | getMotorNumber ()=0 |
| returns number of motors | |
Protected Member Functions | |
| void | setName (const char *name) |
| sets the name of the robot (only for child classes) | |
Protected Attributes | |
| string | name |
|
|
Constructor.
Definition at line 85 of file abstractrobot.h. |
|
|
Definition at line 89 of file abstractrobot.h. |
|
|
returns number of motors
Implemented in ComponentToRobot, Arm2Segm, ForcedSphere, Formel1, HurlingSnake, MuscledArm, Nimm2, Nimm4, Schlange, SchlangeForce, SchlangeServo, SchlangeServo2, SchlangeVelocity, ShortCircuit, Sphererobot, and Sphererobot3Masses. |
|
|
returns the name of the robot
Reimplemented in ComponentToRobot, Arm2Segm, HurlingSnake, MuscledArm, and Schlange. Definition at line 92 of file abstractrobot.h. |
|
|
returns number of sensors
Implemented in ComponentToRobot, Arm2Segm, ForcedSphere, Formel1, HurlingSnake, MuscledArm, Nimm2, Nimm4, Schlange, SchlangeForce, SchlangeServo, SchlangeServo2, SchlangeVelocity, ShortCircuit, Sphererobot, and Sphererobot3Masses. |
|
||||||||||||
|
returns actual sensorvalues
Implemented in ComponentToRobot, Arm2Segm, ForcedSphere, Formel1, HurlingSnake, MuscledArm, Nimm2, Nimm4, Schlange, SchlangeForce, SchlangeServo, SchlangeServo2, SchlangeVelocity, ShortCircuit, Sphererobot, and Sphererobot3Masses. |
|
||||||||||||
|
sets actual motorcommands
Implemented in ComponentToRobot, Arm2Segm, ForcedSphere, Formel1, HurlingSnake, MuscledArm, Nimm2, Nimm4, Schlange, SchlangeForce, SchlangeServo, SchlangeServo2, SchlangeVelocity, ShortCircuit, Sphererobot, and Sphererobot3Masses. |
|
|
sets the name of the robot (only for child classes)
Definition at line 118 of file abstractrobot.h. |
|
|
Reimplemented in Arm2Segm, and MuscledArm. Definition at line 121 of file abstractrobot.h. |
 1.4.5