#include <oneaxisservo.h>
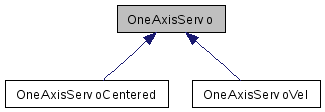
Inherited by OneAxisServoCentered, and OneAxisServoVel.
Inheritance diagram for OneAxisServo:
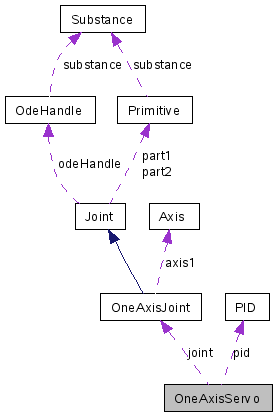
Public Member Functions | |
| OneAxisServo (OneAxisJoint *joint, double _min, double _max, double power, double damp=0.2, double integration=2, double maxVel=10.0, double jointLimit=1.3, bool minmaxCheck=true) | |
| min and max values are understood as travel bounds. | |
| virtual | ~OneAxisServo () |
| virtual void | set (double pos) |
| sets the set point of the servo. | |
| virtual double | get () |
| returns the position of the slider in ranges [-1, 1] (scaled by min, max) | |
| virtual void | setMinMax (double _min, double _max) |
| virtual void | setPower (double power) |
| adjusts the power of the servo | |
| virtual double | getPower () |
| returns the power of the servo | |
| virtual double & | damping () |
| returns the damping of the servo | |
| virtual double & | offsetCanceling () |
| returns the damping of the servo | |
| virtual void | setMaxVel (double maxVel) |
| adjusts maximal speed of servo | |
| virtual double | getMaxVel () |
| adjusts maximal speed of servo | |
Protected Attributes | |
| OneAxisJoint * | joint |
| double | min |
| double | max |
| PID | pid |
| double | maxVel |
| double | jointLimit |
| joint limit with respect to servo limit | |
| OneAxisServo | ( | OneAxisJoint * | joint, | |
| double | _min, | |||
| double | _max, | |||
| double | power, | |||
| double | damp = 0.2, |
|||
| double | integration = 2, |
|||
| double | maxVel = 10.0, |
|||
| double | jointLimit = 1.3, |
|||
| bool | minmaxCheck = true | |||
| ) | [inline] |
min and max values are understood as travel bounds.
Min should be less than 0.
| virtual ~OneAxisServo | ( | ) | [inline, virtual] |
| virtual double& damping | ( | ) | [inline, virtual] |
returns the damping of the servo
| virtual double get | ( | ) | [inline, virtual] |
returns the position of the slider in ranges [-1, 1] (scaled by min, max)
Reimplemented in OneAxisServoCentered, and OneAxisServoVel.
| virtual double getMaxVel | ( | ) | [inline, virtual] |
| virtual double getPower | ( | ) | [inline, virtual] |
| virtual double& offsetCanceling | ( | ) | [inline, virtual] |
| virtual void set | ( | double | pos | ) | [inline, virtual] |
sets the set point of the servo.
Position must be between -1 and 1. It is scaled to fit into min, max
Reimplemented in OneAxisServoCentered, and OneAxisServoVel.
| virtual void setMaxVel | ( | double | maxVel | ) | [inline, virtual] |
| virtual void setMinMax | ( | double | _min, | |
| double | _max | |||
| ) | [inline, virtual] |
| virtual void setPower | ( | double | power | ) | [inline, virtual] |
OneAxisJoint* joint [protected] |
double jointLimit [protected] |
joint limit with respect to servo limit
double max [protected] |
double maxVel [protected] |
double min [protected] |
 1.4.7