#include <speedsensor.h>
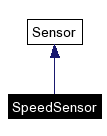
Inherits Sensor.
Inheritance diagram for SpeedSensor:
Public Types | |
| enum | Mode { Translational, Rotational } |
| Sensor mode. More... | |
Public Member Functions | |
| SpeedSensor (double maxSpeed, Mode mode=Translational, short dimensions=X|Y|Z) | |
| virtual | ~SpeedSensor () |
| virtual void | init (Primitive *own) |
| initialises sensor with body of robot. | |
| virtual int | getSensorNumber () const |
| returns the number of sensors values produced by this sensor | |
| virtual bool | sense (const GlobalData &globaldata) |
| performs sense action | |
| virtual std::list< sensor > | get () const |
| returns a list of sensor values (usually in the range [0,1] ) | |
| virtual int | get (sensor *sensors, int length) const |
| writes the sensor values (usually in the range [0,1] ) into the giben sensor array and returns the number of sensors written | |
Private Attributes | |
| double | maxSpeed |
| Mode | mode |
| short | dimensions |
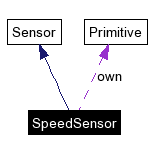
| Primitive * | own |
The sensor values are normalised speeds, either translational or rotational
|
|
Sensor mode.
|
|
||||||||||||||||
|
|
|
|
|
|
||||||||||||
|
writes the sensor values (usually in the range [0,1] ) into the giben sensor array and returns the number of sensors written
Implements Sensor.
|
|
|
returns a list of sensor values (usually in the range [0,1] )
Implements Sensor.
|
|
|
returns the number of sensors values produced by this sensor
Implements Sensor.
|
|
|
initialises sensor with body of robot. This is usually done by the robot itself. Implements Sensor.
|
|
|
performs sense action
Implements Sensor.
|
|
|
|
|
|
|
|
|
|
|
|
|
 1.3.8